01 / The journey
My first robot
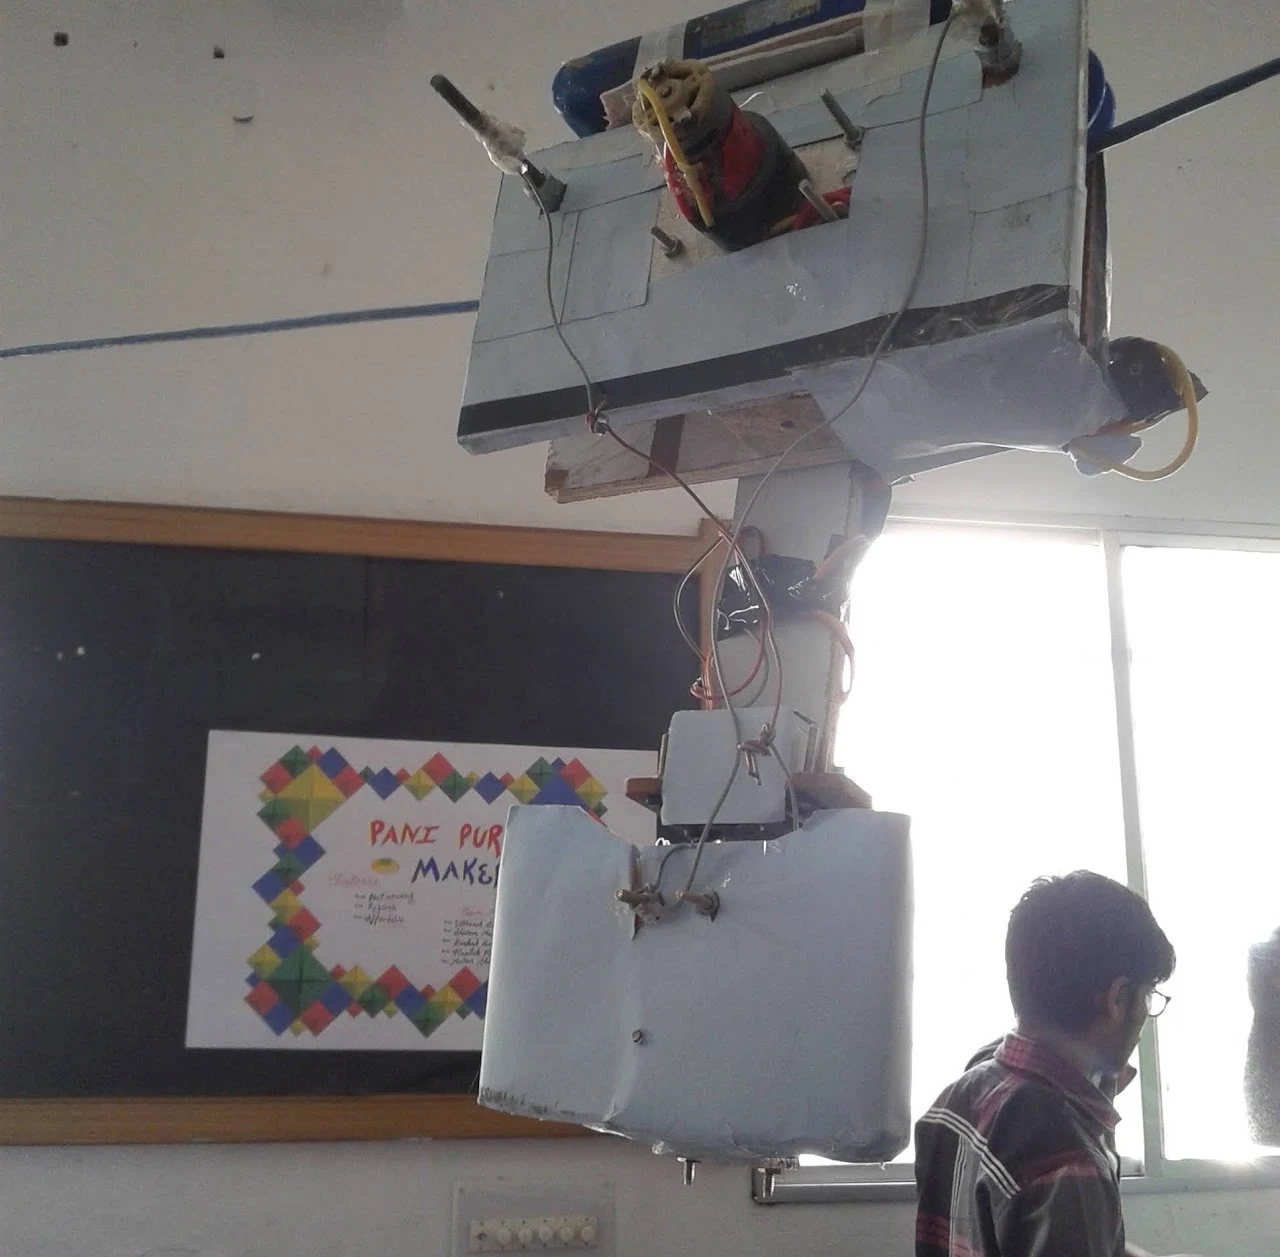
My first robot was a basic rope crawler that moved along a rope using a pulley mechanism and could stream video through an attached mobile camera. Working on this project taught me fundamental skills in machining, mechanical design, and embedded systems.
02 / The journey
Differential Drive
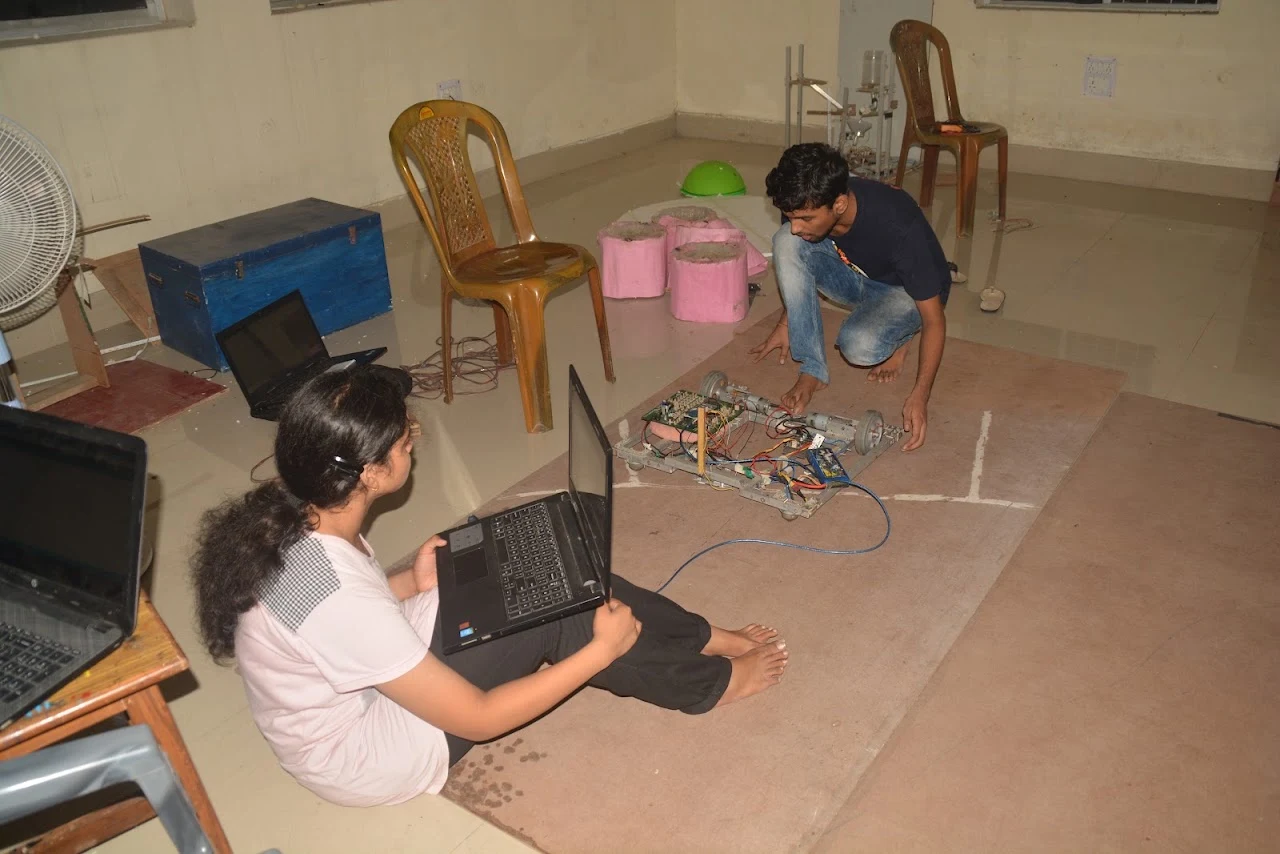
My second project involved controlling a differential drive robot, which introduced me to PID (Proportional-Integral-Derivative) controllers. This experience sparked my interest in control systems and controller design.
03 / The journey
PCB Designing
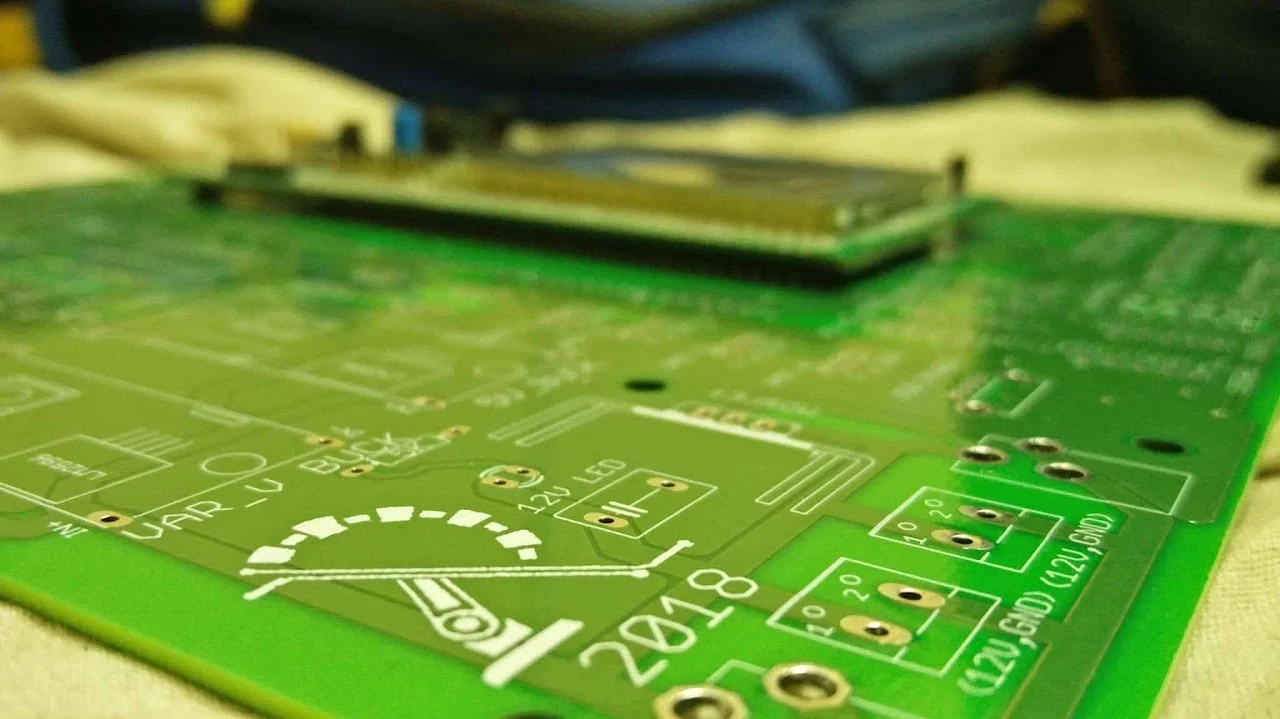
A significant step forward was the design of a double-sided Printed Circuit Board (PCB) for Team Robocon. This project provided a deep understanding of circuits, sensors, actuators, and microcontrollers.
04 / The journey
Robocon 2016 — Asobi
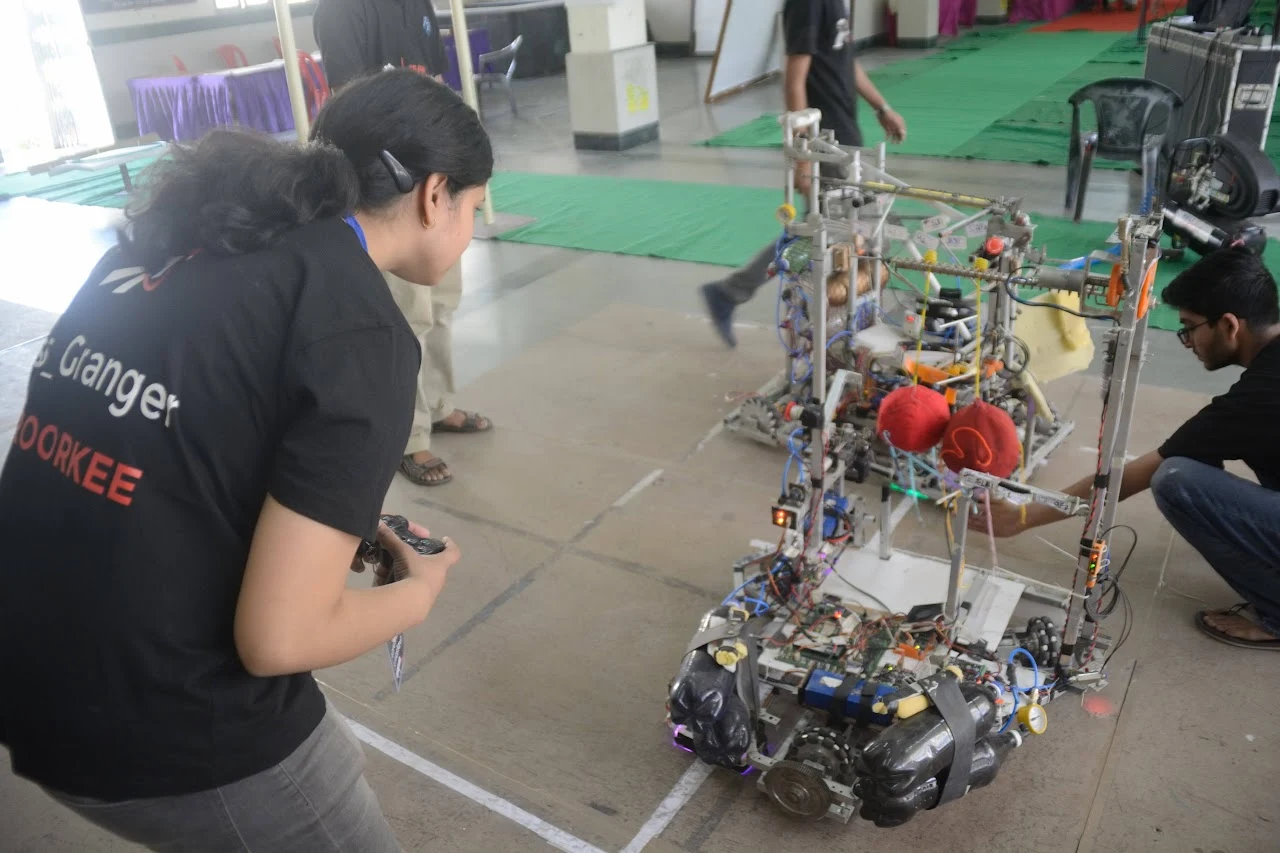
I was a member of Team Robocon at IIT Roorkee, where I competed in ABU Robocon, an annual robotics competition for university, college, and polytechnic students across the Asia-Pacific region. My role involved working on embedded systems, PCB design, and robot control, which sparked a deep interest in robotics for me.
05 / The journey
Robocon 2017- Nem-Con
In this project, my autonomous robot was required to perform various tasks independently and efficiently. I focused on integrating multiple sensors and developing control algorithms to ensure the accurate execution and optimization of these tasks.
06 / The journey
Biped Robot
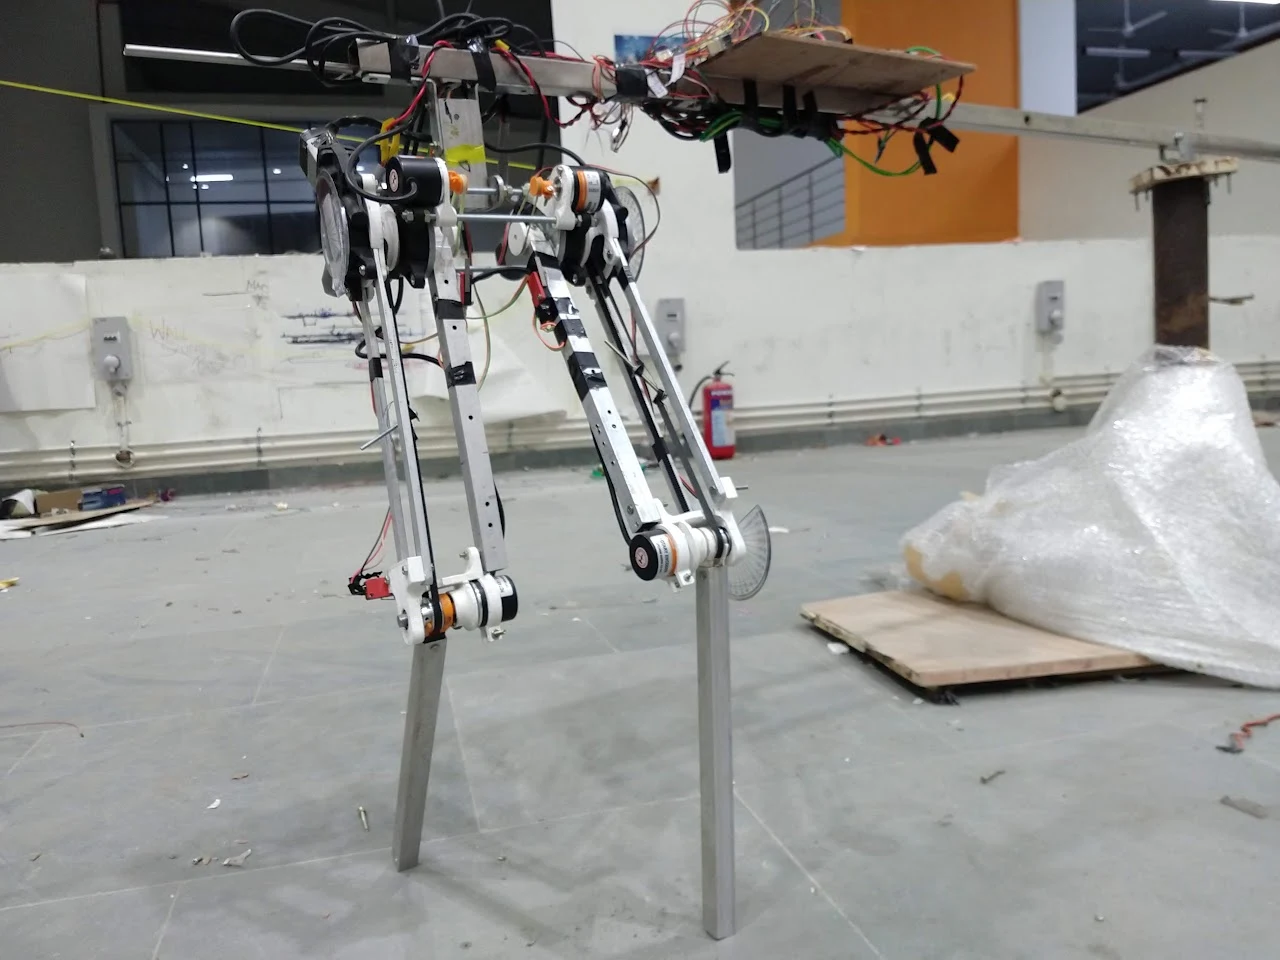
I designed and built a 2-link biped robot in my final year of undergraduate. I also worked on controlling the robot. This project ignited my fascination with legged robots, particularly bipeds, due to their intricate nature and the challenges they present.
07 / The journey
Cassie
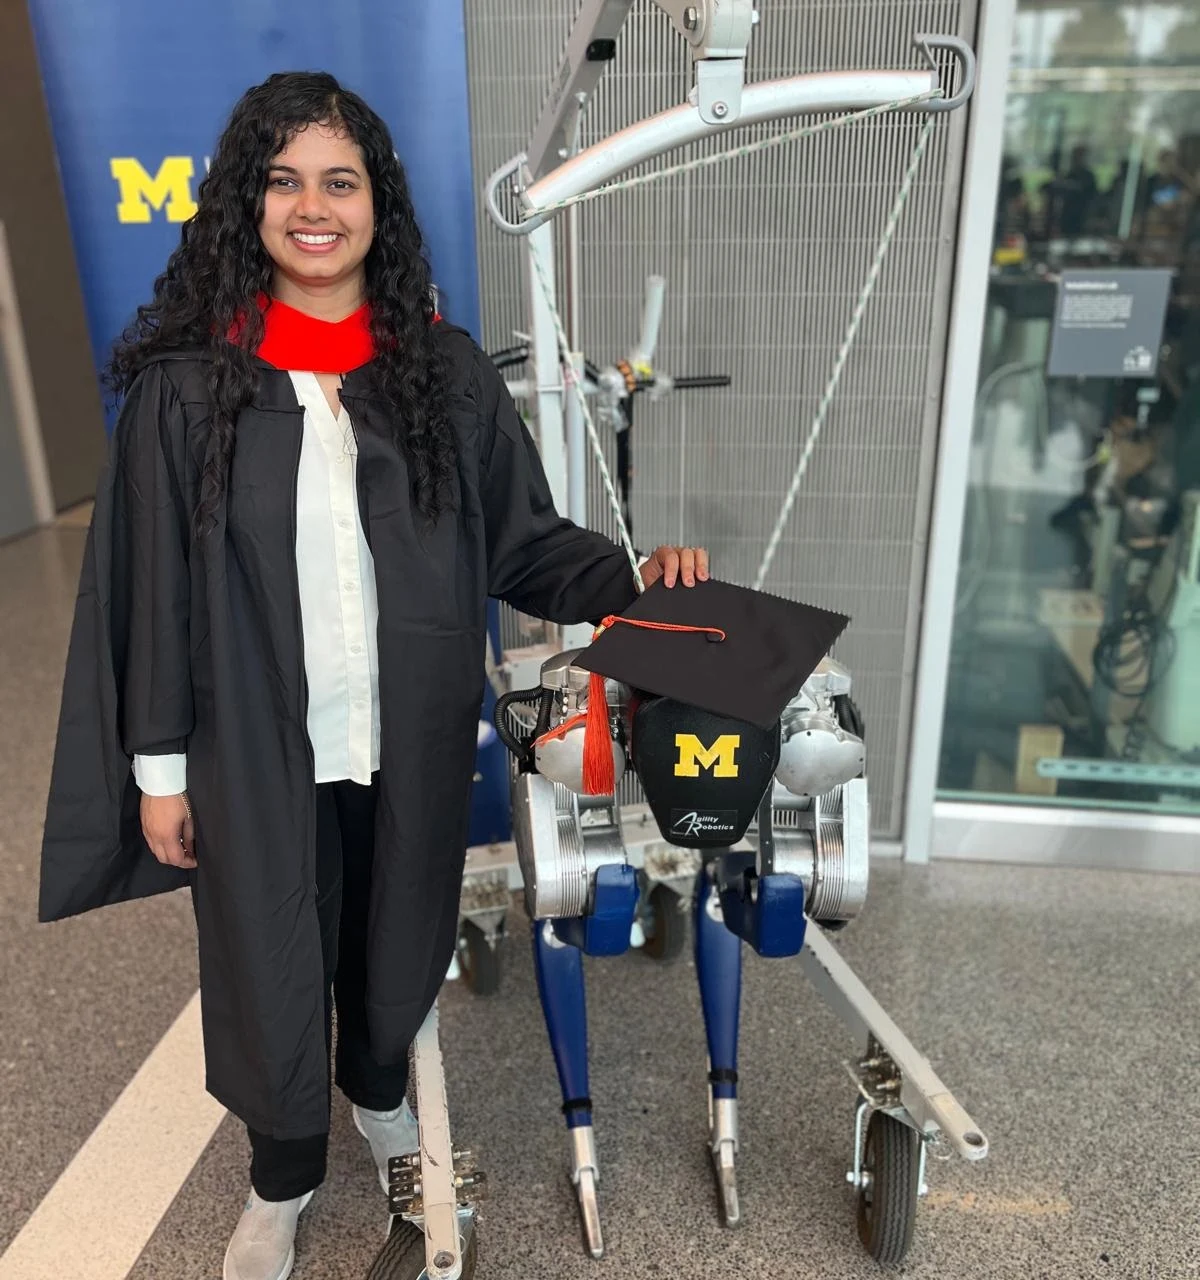
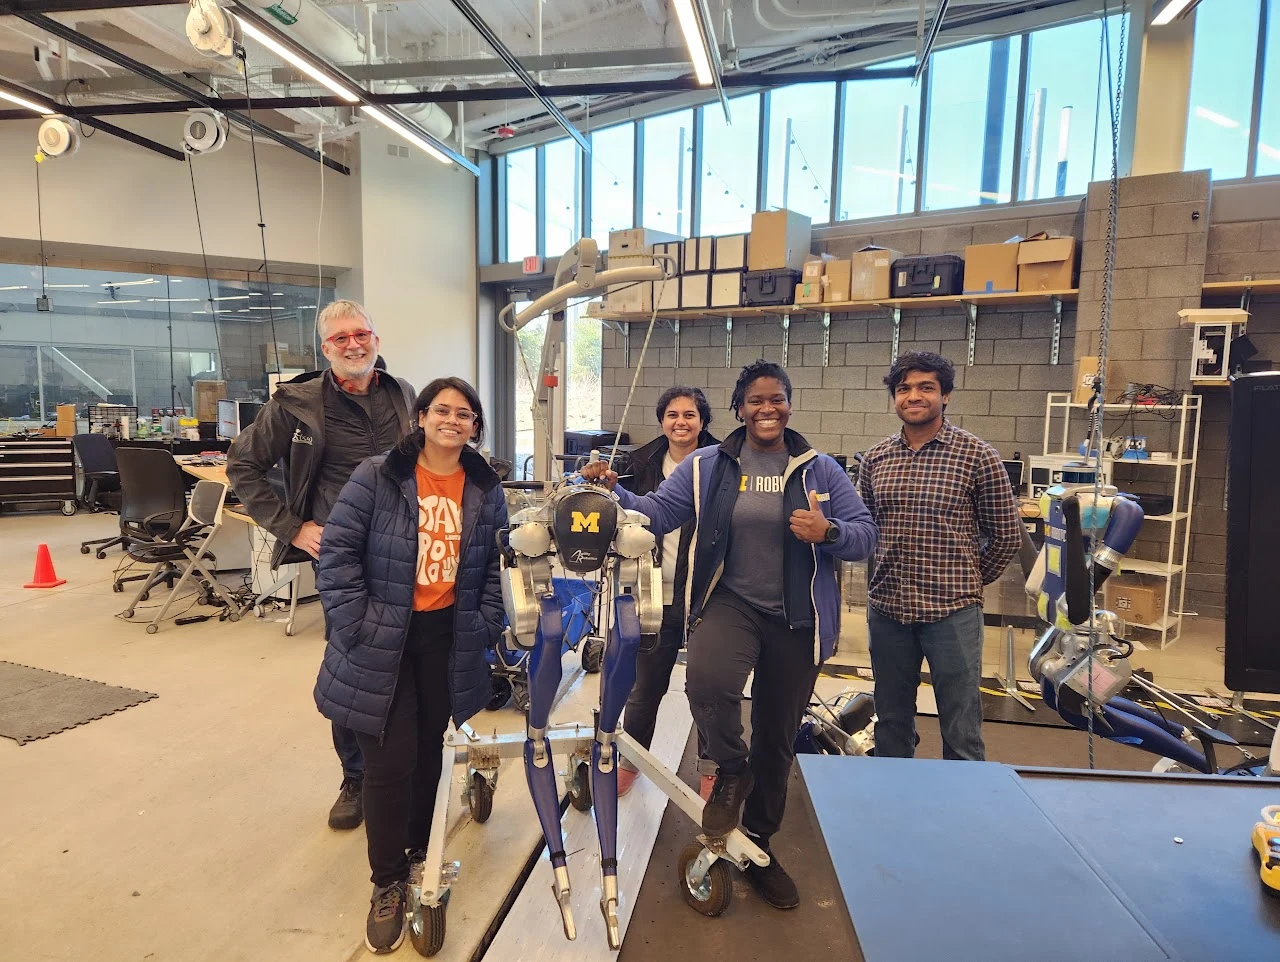
The Cassie project provided extensive knowledge in both classical and optimization-based control. Experiences from working with Cassie and the Biped Locomotion Lab were instrumental in steering my research interests towards control and motion planning for legged robots.
08 / The journey
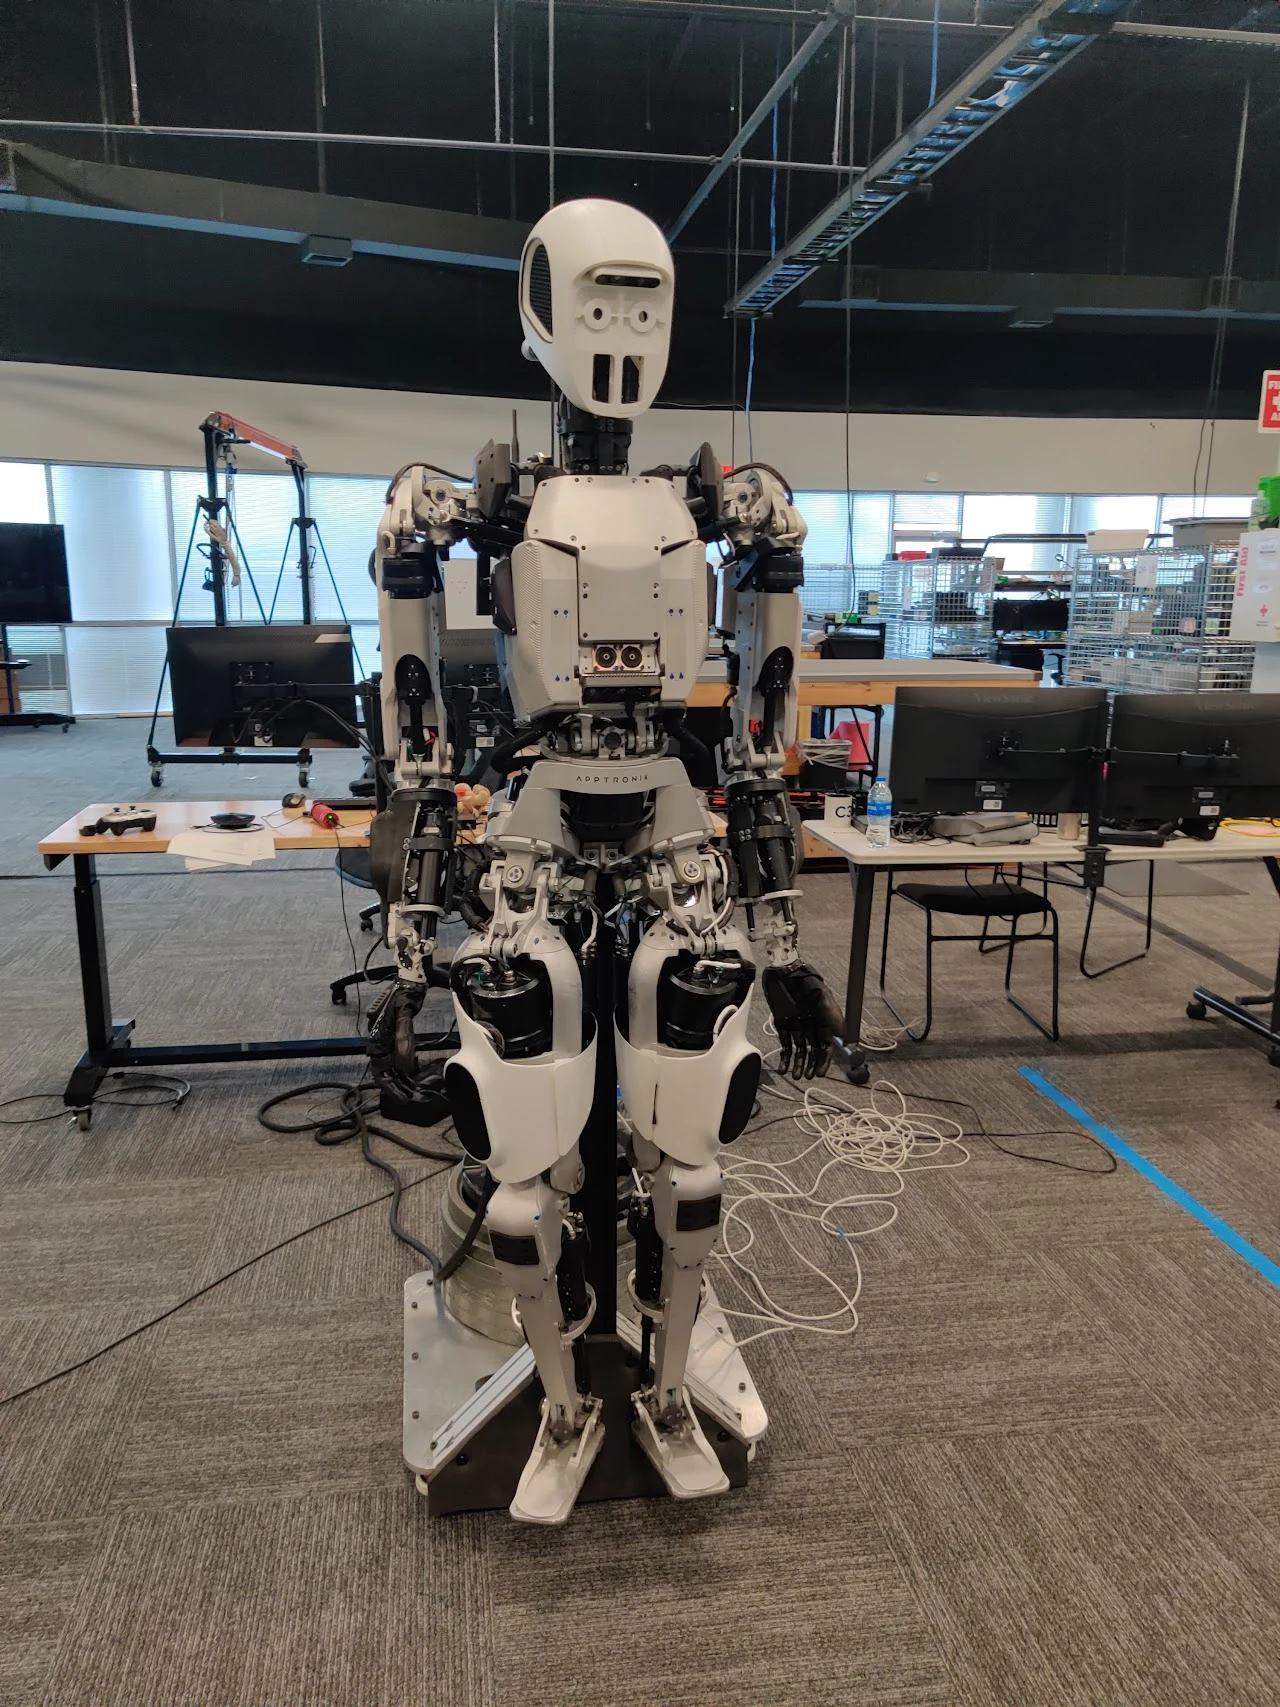
Apollo Humanoid
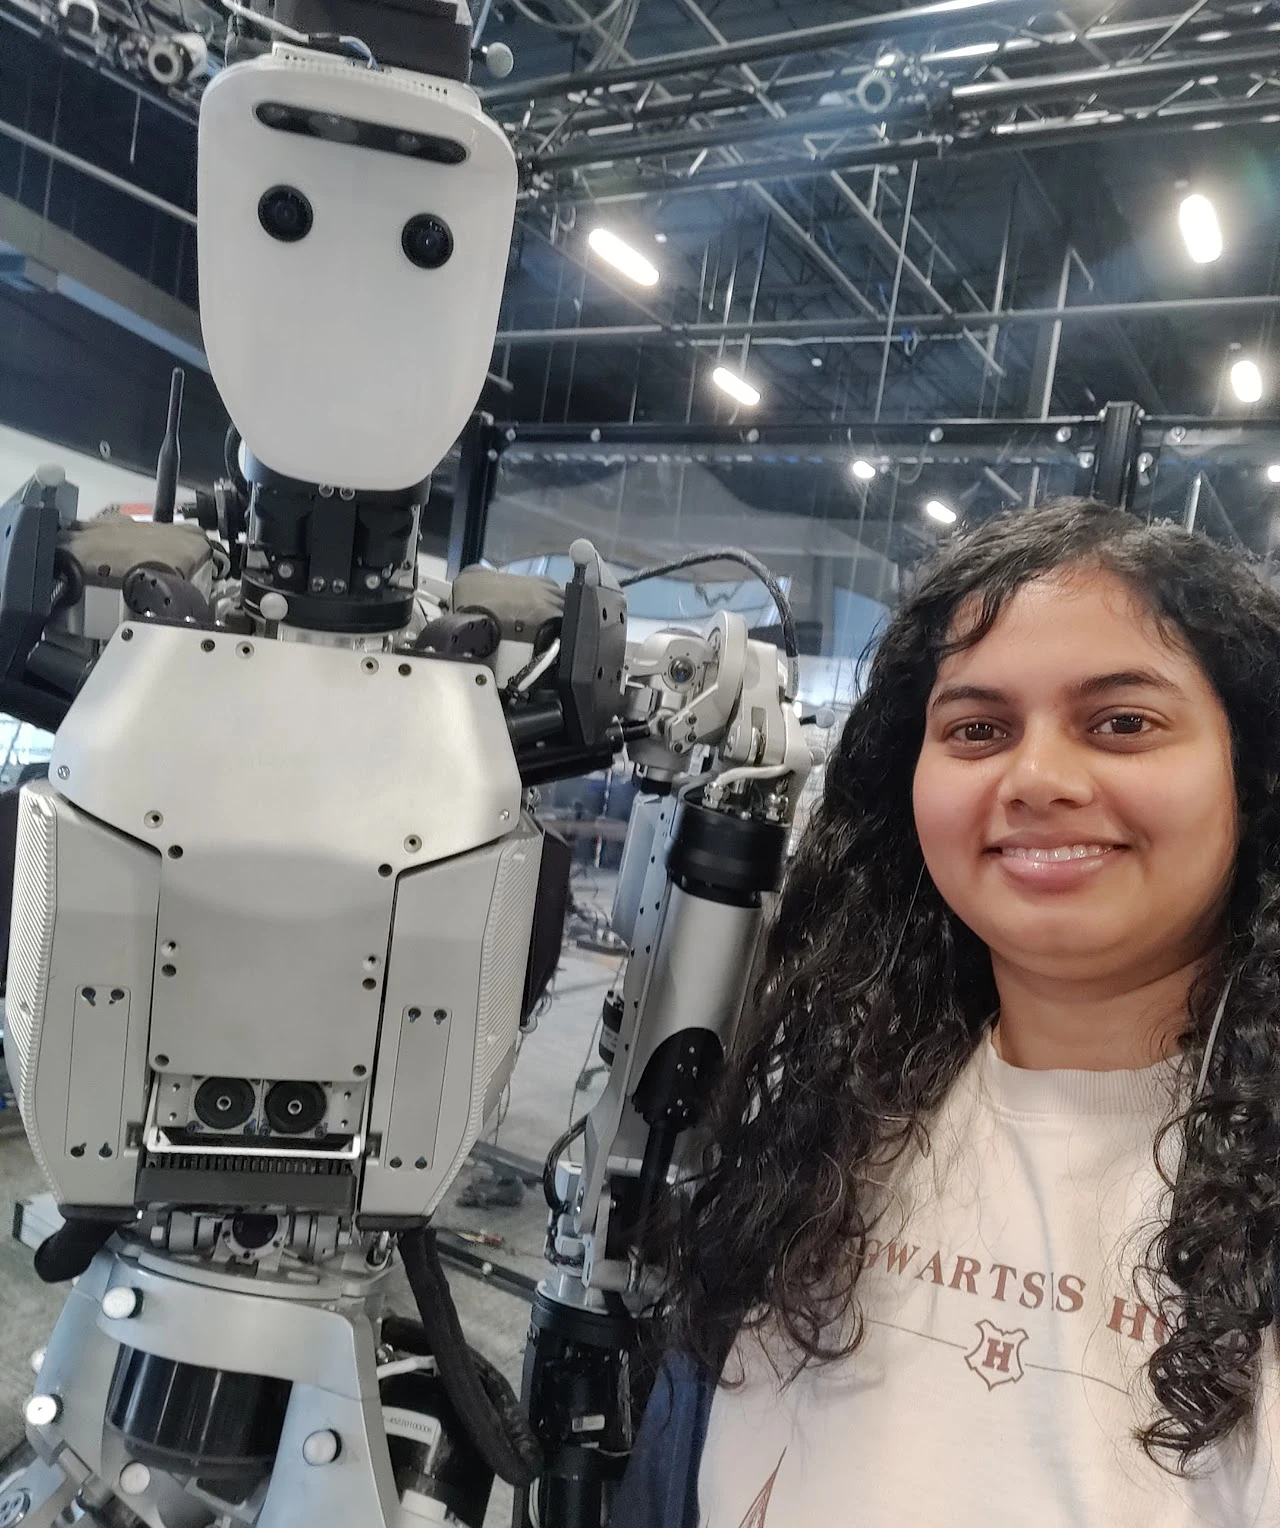
Work on Apptronik's Apollo Humanoid marked my first encounter with a full humanoid robot. This project revealed the exciting possibilities humanoids offer and the intriguing research opportunities they present. Plus, they look super cool!
09 / The journey
xArm Manipulator
Recently, I’ve been hands-on with the xArm manipulator for research. It’s fascinating how different the primary challenges are compared to humanoid robotics. With humanoids, the constant battle is balance and posture. With manipulators, the focus shifts almost entirely to precision and trajectory execution.